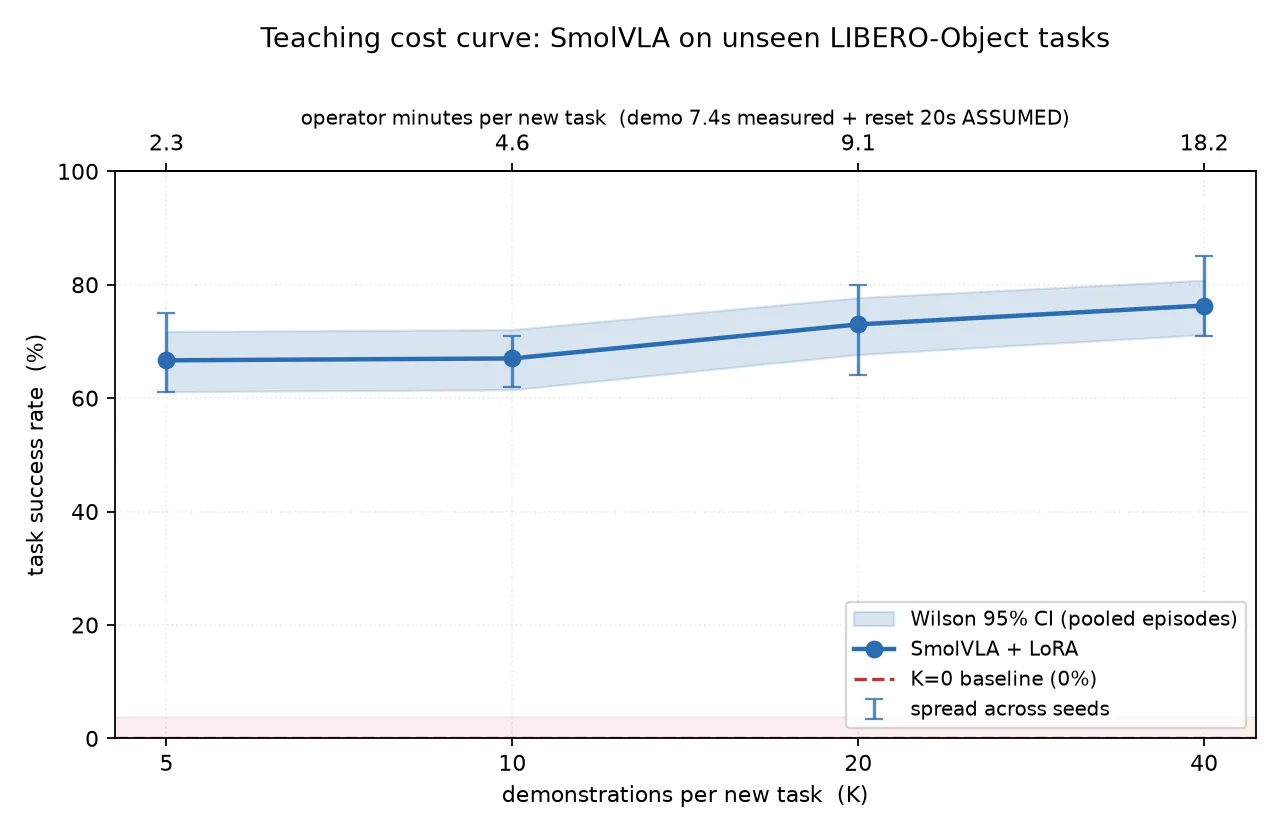
Measuring the demonstration-count vs. success-rate curve for SmolVLA, LoRA fine-tuned on unseen LIBERO tasks, on a single 8 GB consumer GPU. Nearly all of the value arrives in the first five demonstrations, and so does catastrophic forgetting.
TEKNOFEST 2026 Artificial Intelligence in Aviation. I owned the GPS-free positioning task: RAFT optical flow + homography with a keyframe ladder estimates the aircraft’s displacement from its downward camera. Full rehearsal: 2256/2256 frames, 3.54 m mean error.
3.54 m · mean error, full run
RAFT
Homography
OpenCV
PyTorch
Read case studyCode on request
Computer Vision
2026·TEKNOFEST 2026 · 5G & AI Smart Road Safety · Team BiDatalar
Identifies a vehicle (body type, plate, colour) and detects driver-caused violations from a single night-time pass through the windshield. Built on one rule: nothing that cannot be proven is reported. Result: zero false positives.
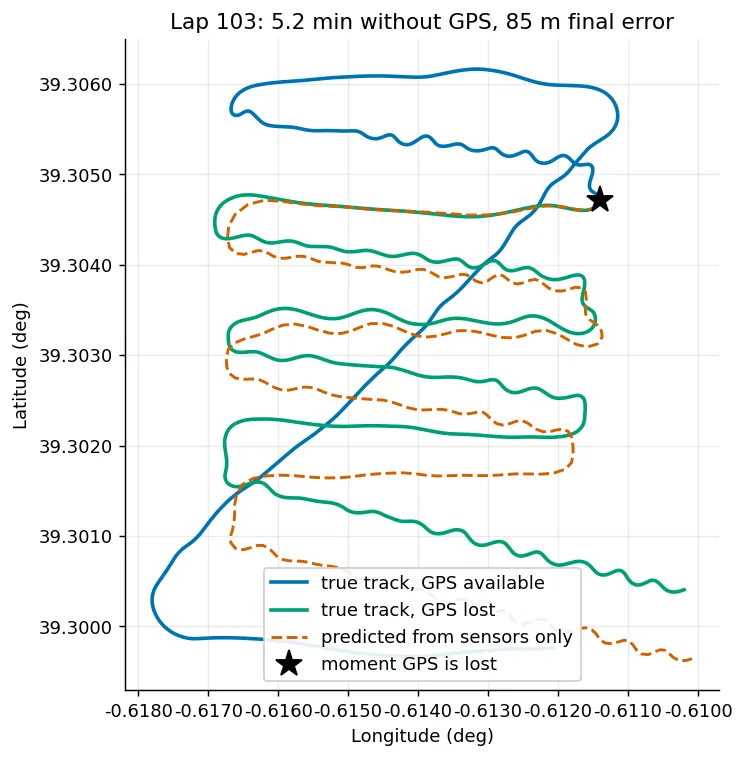
Neural dead reckoning for a fixed-wing UAV: an LSTM predicts one-second displacements from 19 GPS-free sensor channels. After 4.5 minutes without GPS it is still within ~85 m, about 38× better than classical dead reckoning.
ROS 2 Humble autonomy stack for a 4×4 unmanned ground vehicle on Jetson Orin NX: SLAM, EKF sensor fusion, Nav2, a slalom planner and a finite-state-machine mission manager, developed in Gazebo simulation first.
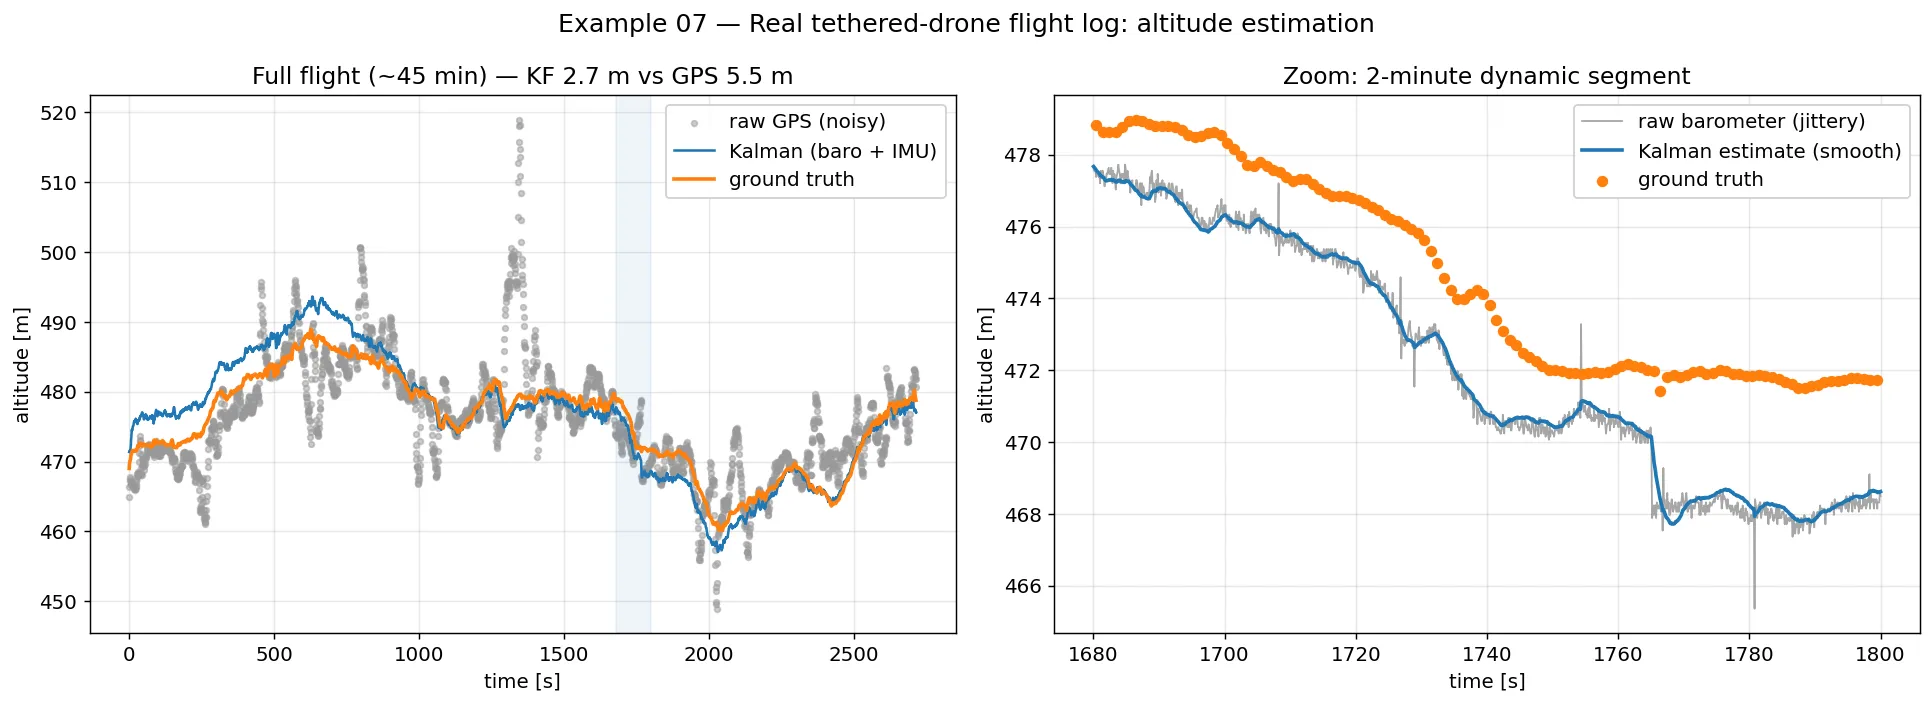
A hands-on state-estimation library: KF and EKF implemented from scratch in NumPy, with seven progressive examples from 1D tracking to sensor fusion, EKF radar and a real drone flight-log case study.
Missense genetic variants → pathogenic / benign, with ~55% missing features and a train/test prior shift. Leakage-controlled validation, Optuna-tuned gradient-boosting ensemble and SHAP explanations.
Flutter app for organising group Quran readings and dhikr collections: 30-juz assignment grid, real-time group chat, discover feed and abuse protection. Firebase Auth, Firestore and FCM.
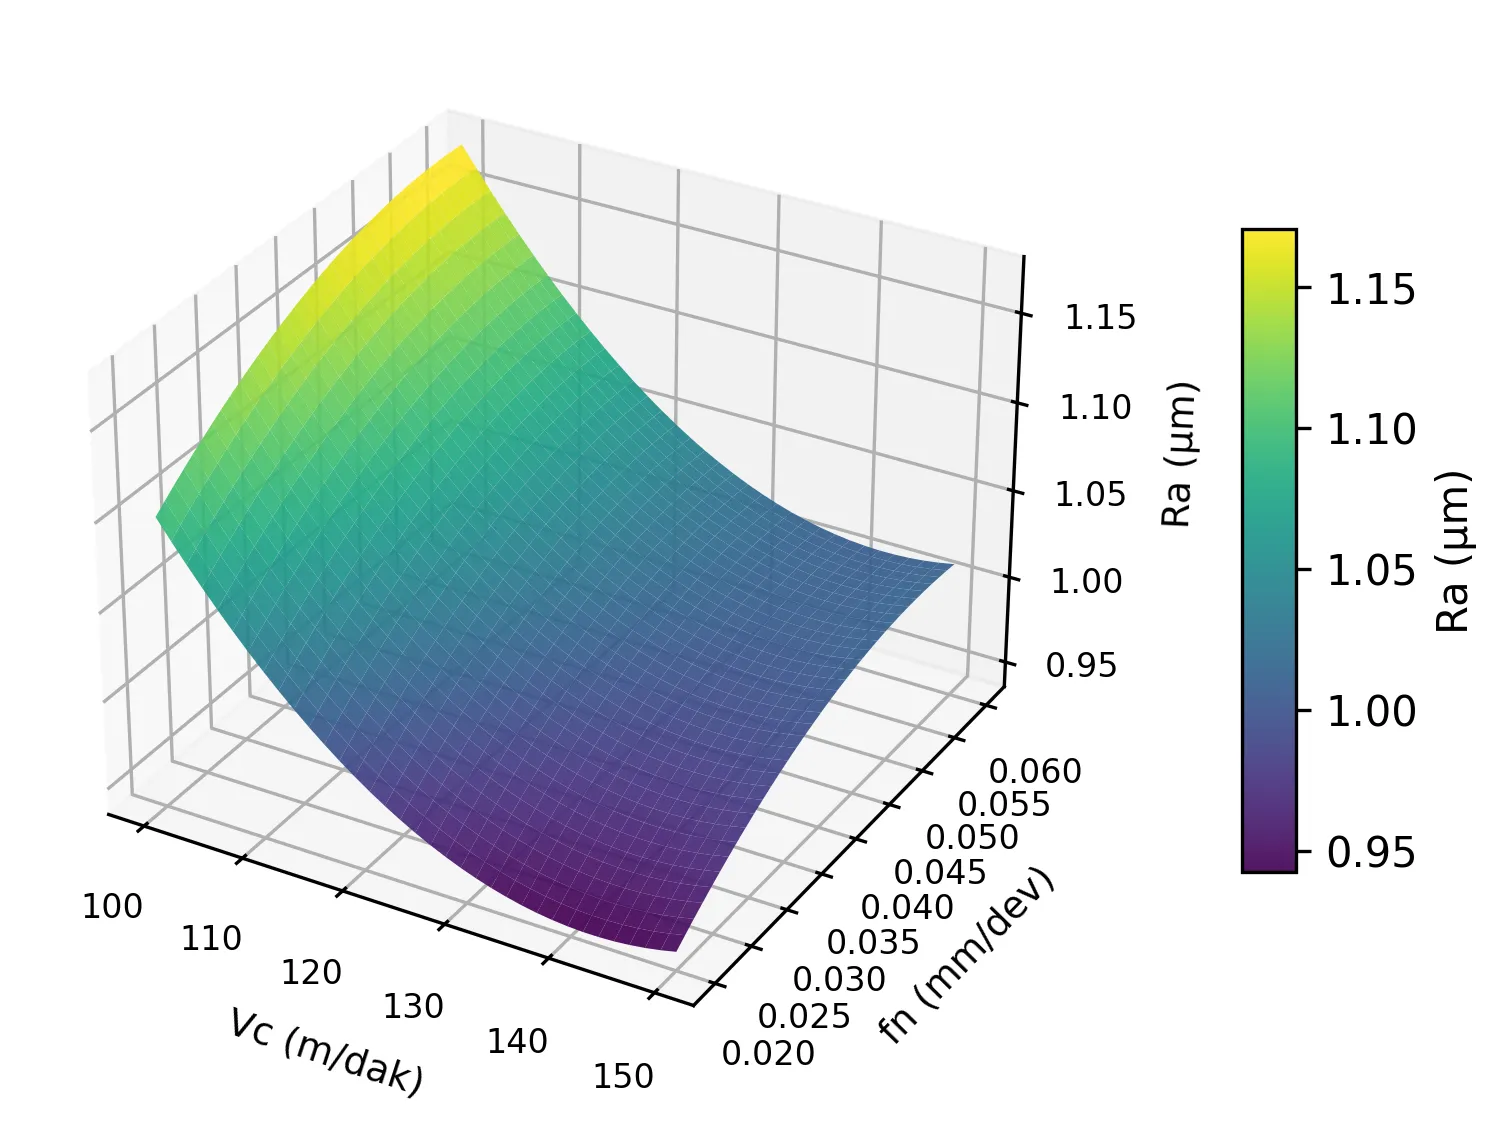
Graduation project in the TUSAŞ Lift Up program. Five regressors compared under three cross-validation schemes on a Taguchi L9 design; the RSM model reaches CV R² = 0.978. Shipped as a desktop app, standalone .exe and Flask REST API.
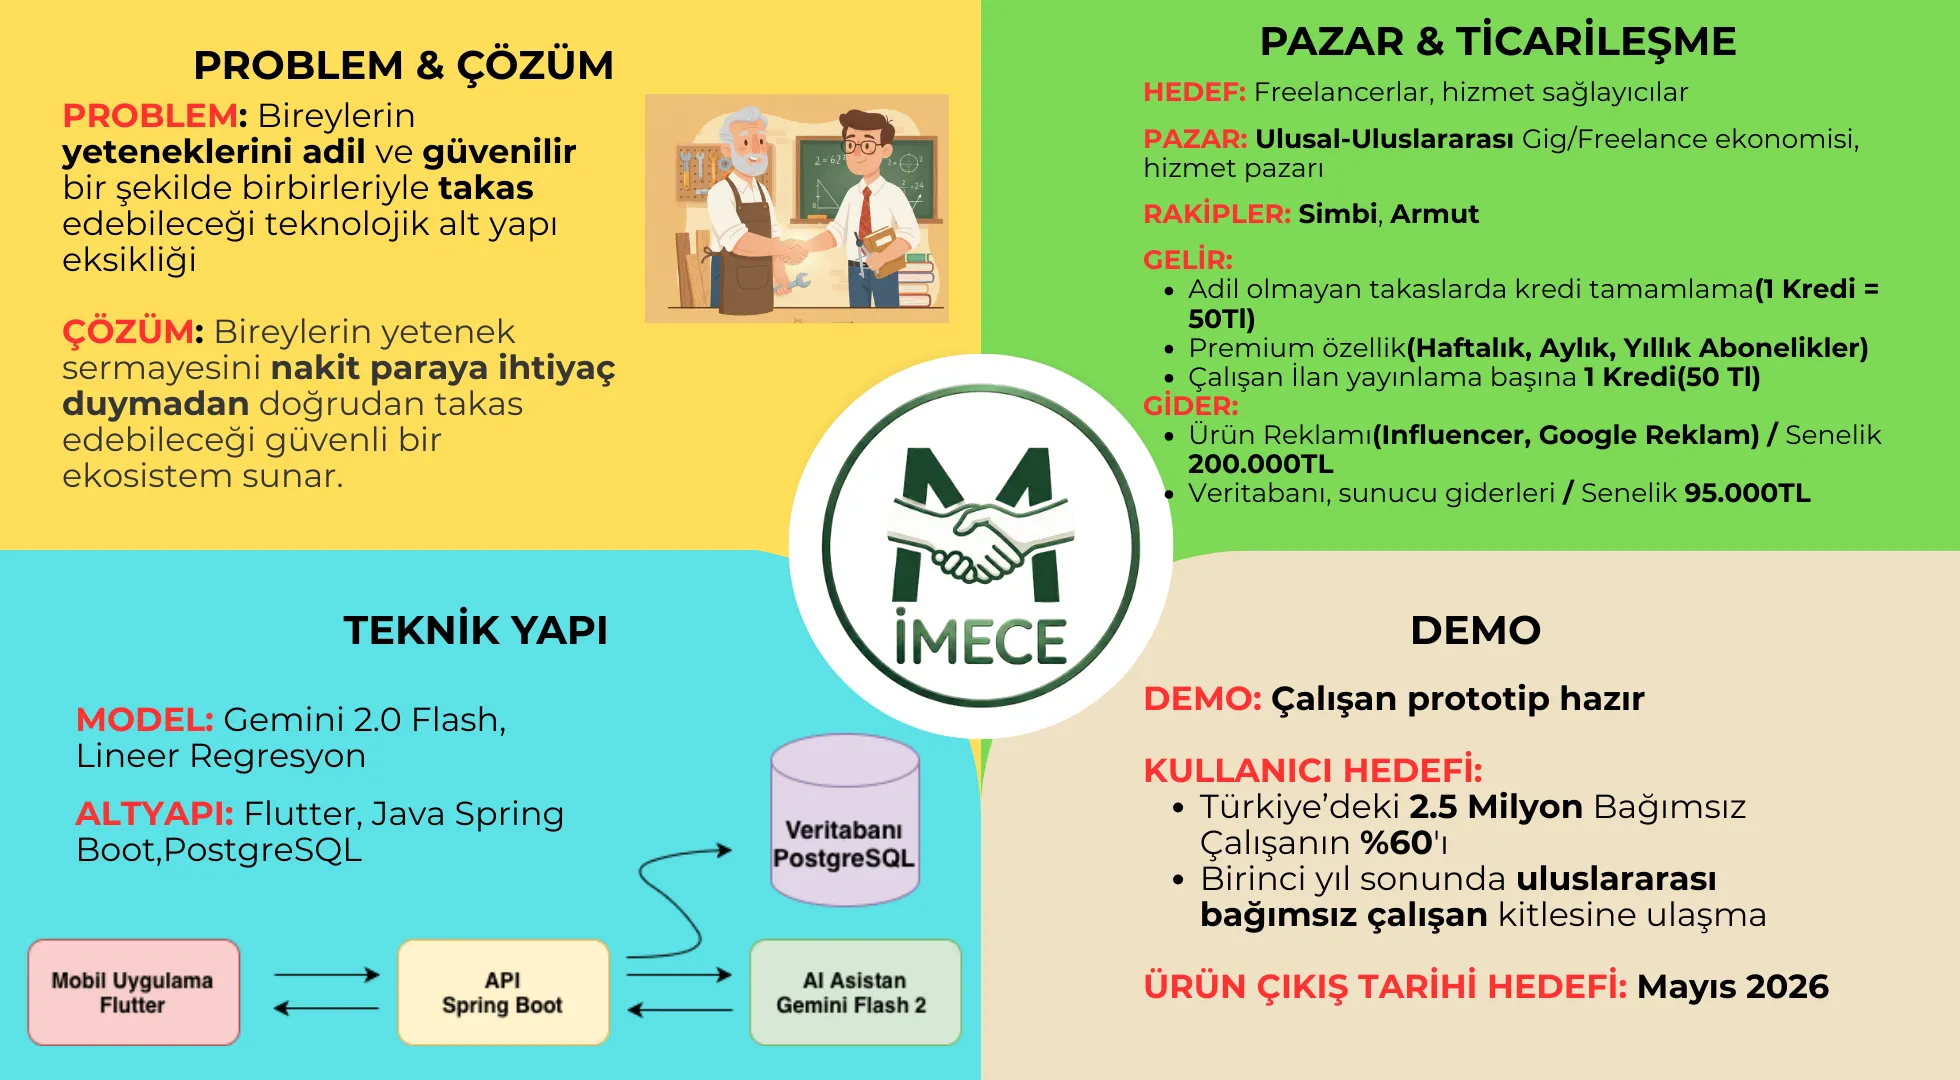
Two-sided skill-exchange marketplace with trust, credit-balance and fairness scores: Spring Boot backend, Flutter app and an ML credit-scoring regression.
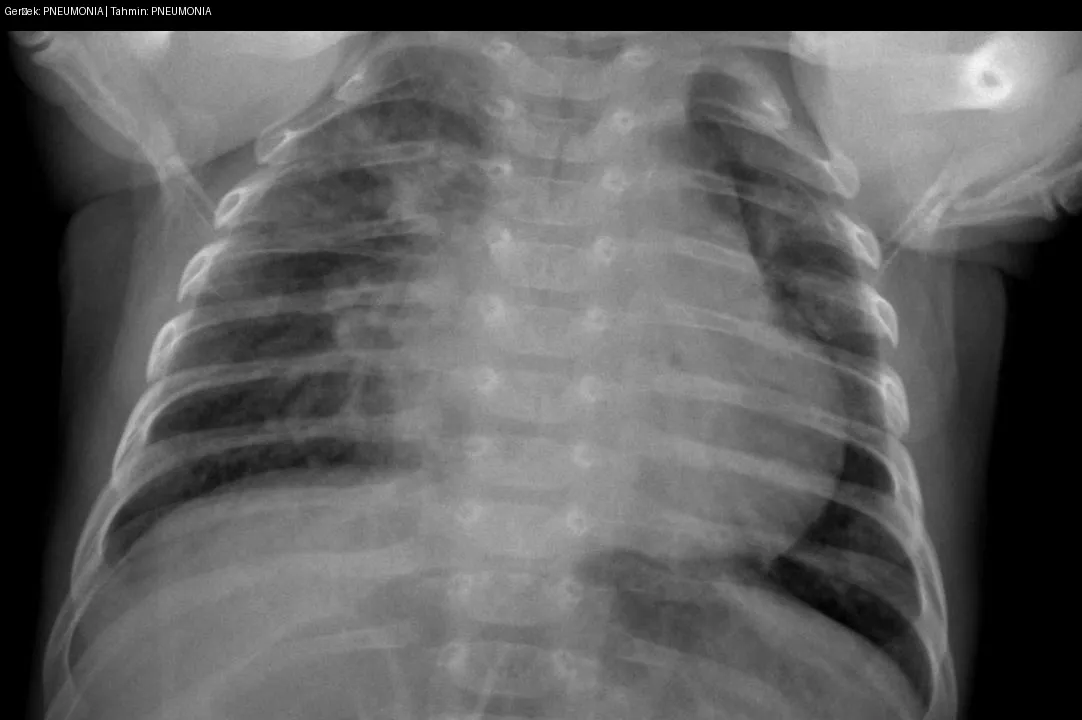
Eight mini-projects across computer vision and NLP: pneumonia detection with transfer learning, YOLOv8 vehicle tracking, CNN classification, LSTM and a RAG pipeline with FAISS and Gemini.
Neighbourhood super-app: events, groups, real-time chat over STOMP, marketplace, local pros with reviews and maps. Flutter client with a Spring Boot backend.
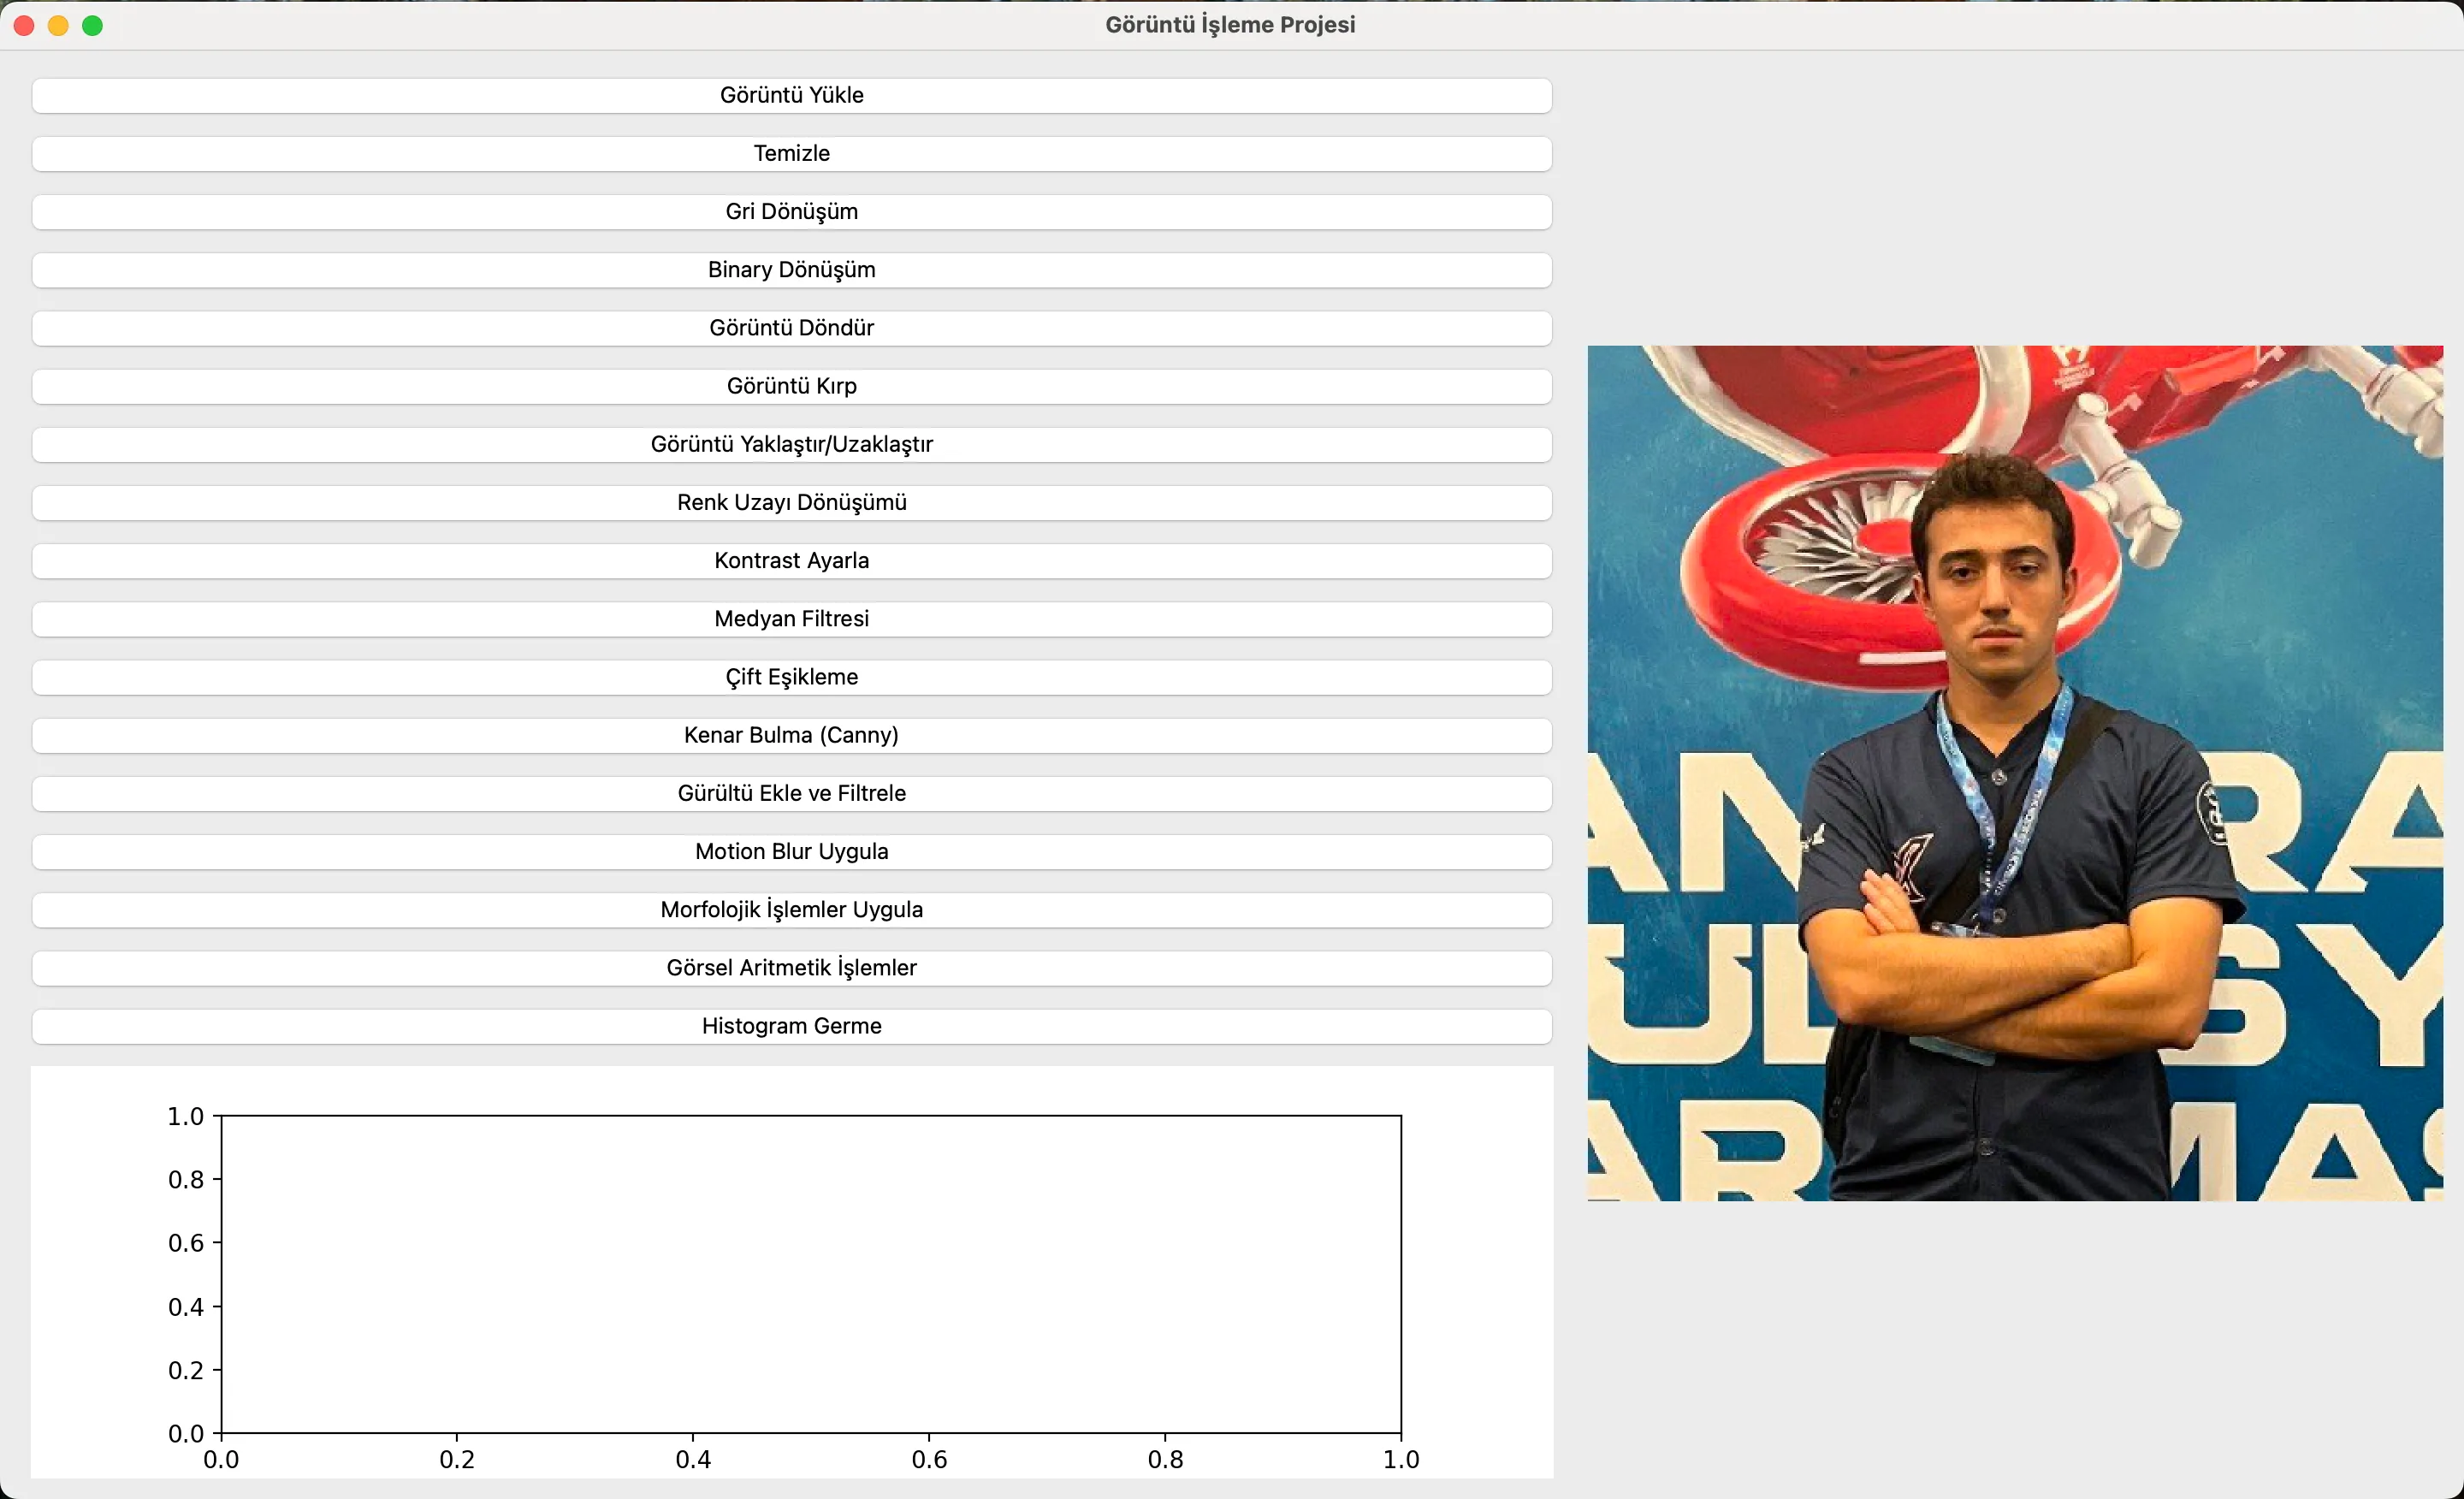
Sixteen classic algorithms (convolution, Canny, histogram equalisation, morphology) written in raw NumPy, no OpenCV filter calls, behind a PyQt5 interface.